OR-WP-2026-001
Continuous arm retargeting without competing trajectory workers
How a detached-worker handoff can corrupt motion continuity, and how a persistent owner was tested before live integration.
Read paperOrbitus Robotics / Research
Building ROB and our security applications exposes practical problems in control, recovery, observation, and trustworthy automation. These papers share what we observed, how we investigated it, and what remains to be tested.
Full web editions, illustrated PDFs, and traceable evidence. Each paper identifies its publication date and evidence boundary.
Robotics and cybersecurity
OR-WP-2026-001
How a detached-worker handoff can corrupt motion continuity, and how a persistent owner was tested before live integration.
Read paperOR-WP-2026-002
A source-bound audit of the Amber host executable, its 42 mapped libraries, and an offline-tested compatibility boundary.
Read paperOR-WP-2026-003
An evidence-based plan for backups, exclusive CAN ownership, fresh controller generations and measured stopping before physical streaming.
Read paperOR-WP-2026-004
A read-only audit of an older AMBER B1 host identifies storage, runtime, timing and model constraints, then defines a staged path to two-arm control.
Read paperOR-WP-2026-005
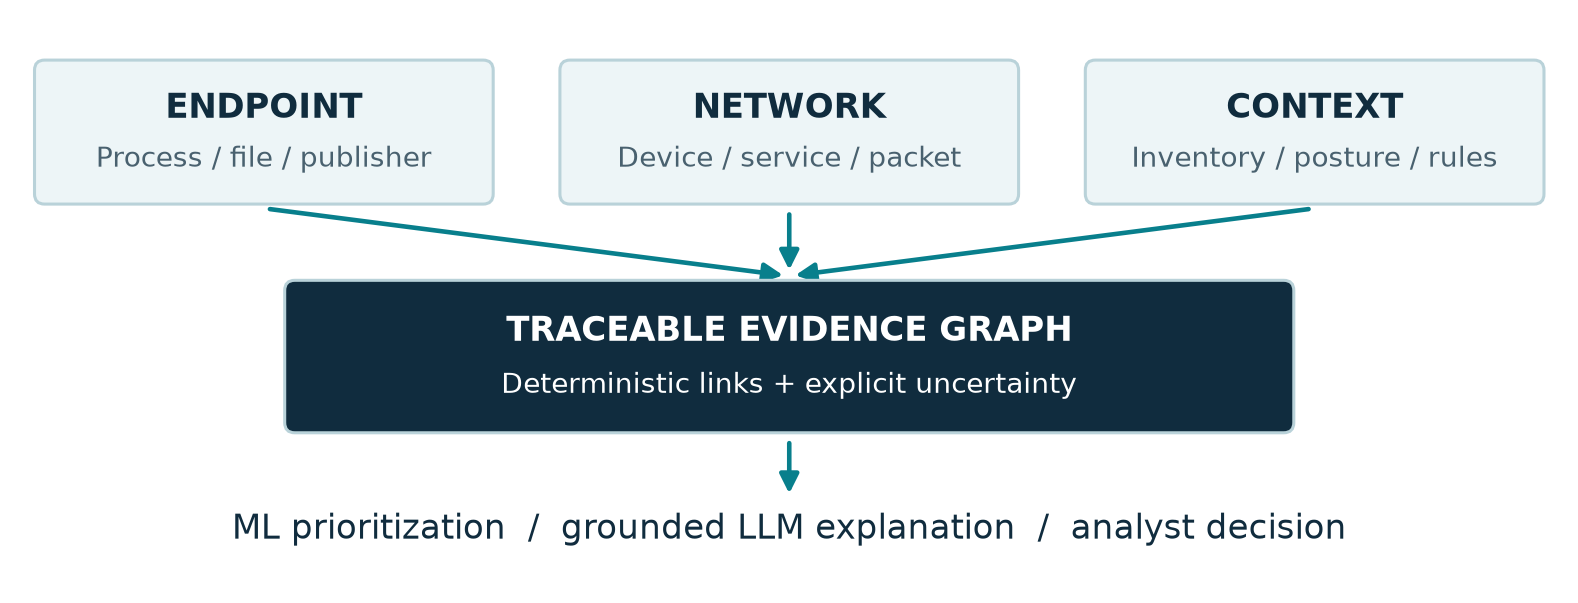
A source-grounded assessment of the Orbitus security suite, its overlap with established tools, and a staged path from endpoint and packet evidence to trustworthy ML-assisted investigation.
Read paperStart with the motion-transition study, then the controller compatibility audit and recovery plan. The fourth paper examines an older X-Hub computer as a dual-arm development candidate. Each paper introduces ROB’s purpose and software context, distinguishes observations from proposals, and identifies the physical measurements still needed.
The fifth paper examines SignalAtlas, BlackViper, Apple Endpoint Security, and the next generation of LLM and machine-learning-assisted threat investigation. Its competitive analysis separates implemented capabilities from proposed integrations.
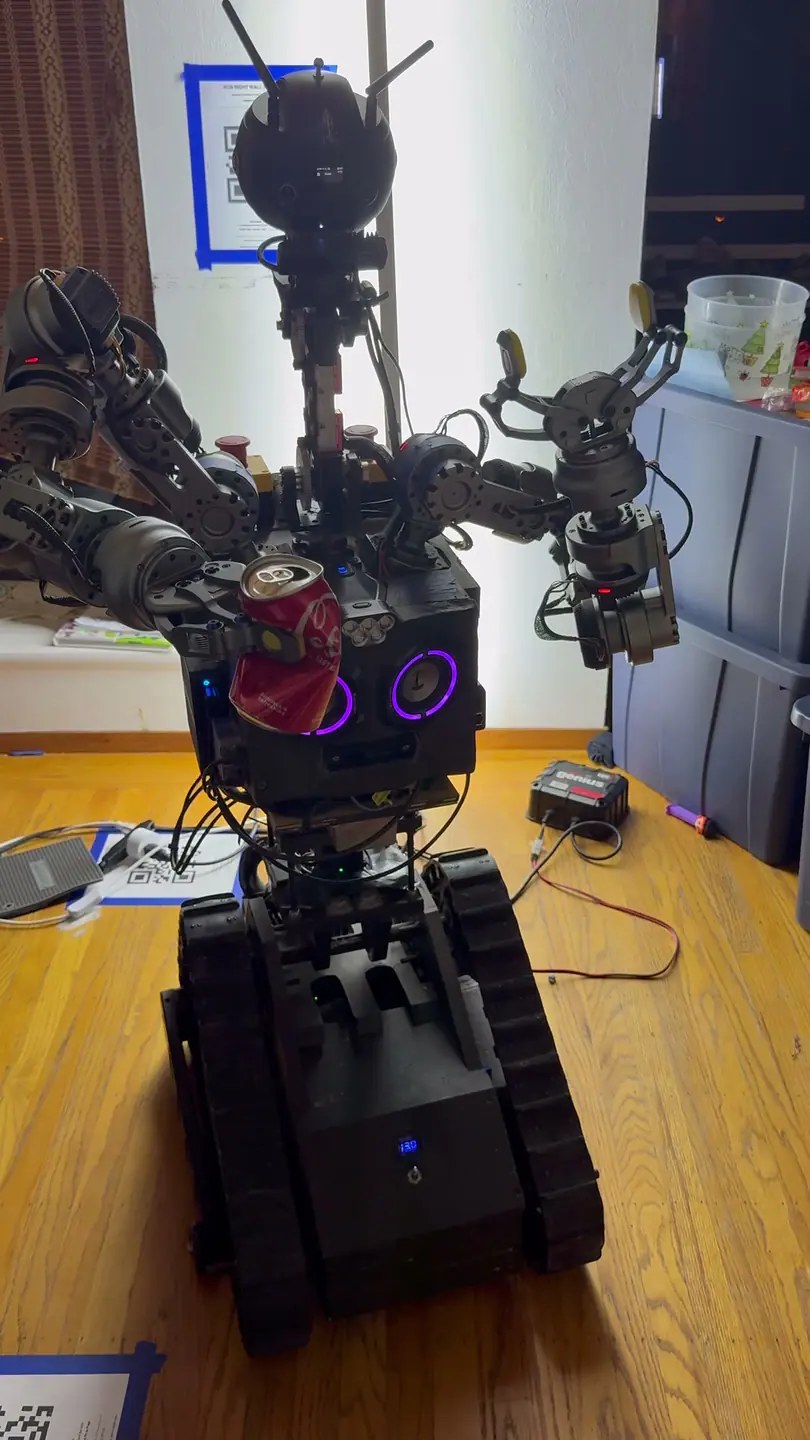
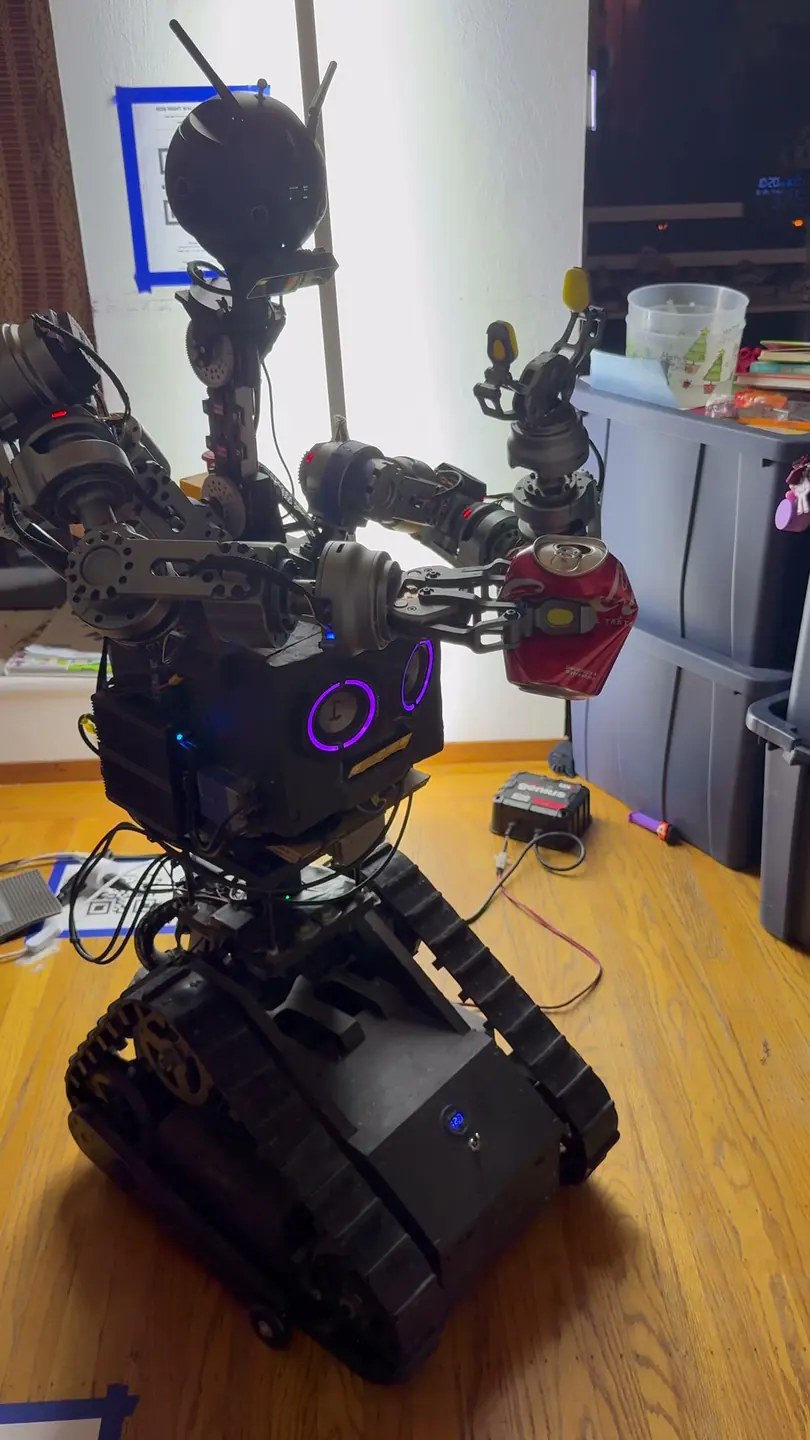
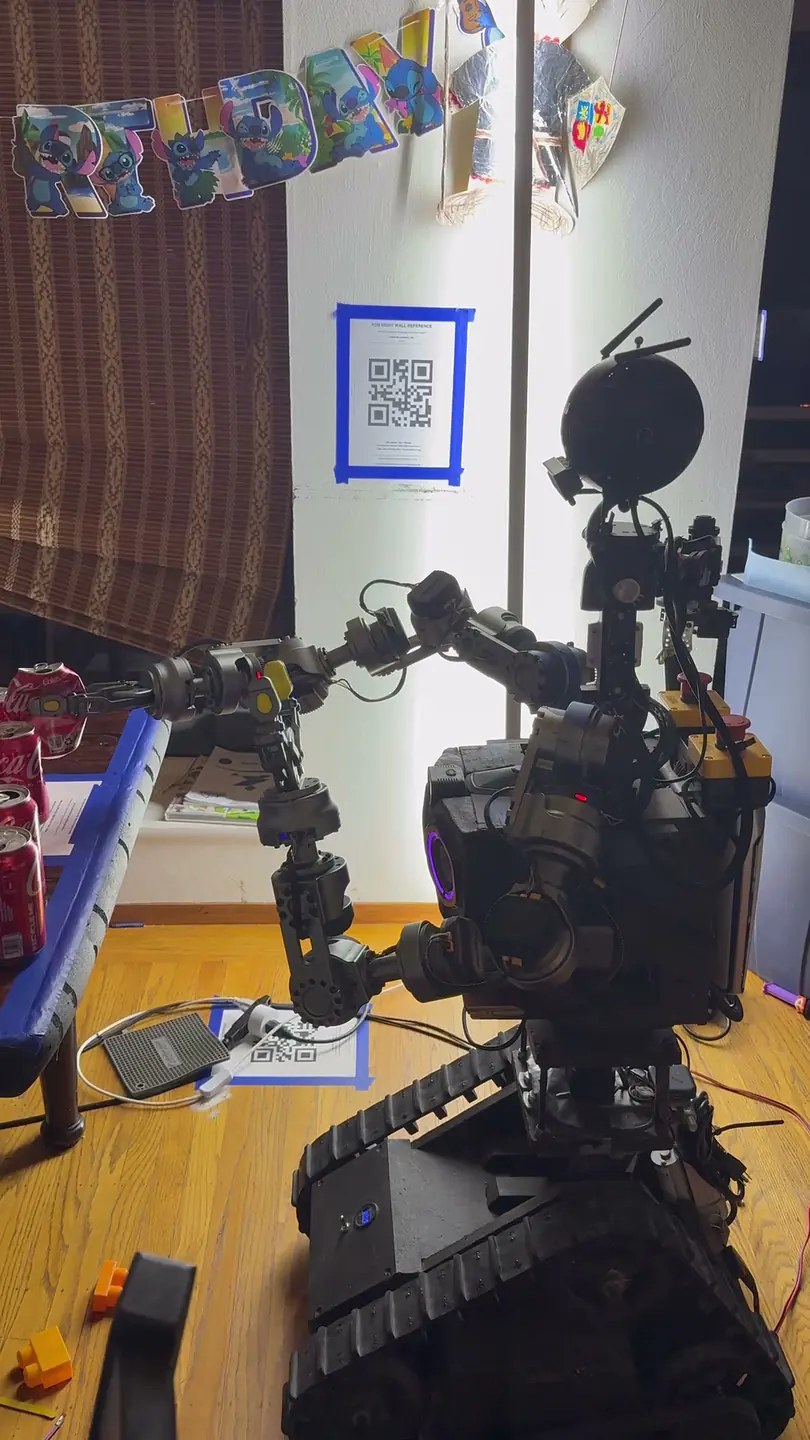
Robotics photos come from Kierie’s October 29 can-handling videos. They document earlier work with ROB; they do not show the replacement controller operating. Security diagrams are original conceptual illustrations.
These are Orbitus Robotics technical white papers, not peer-reviewed journal articles. Each edition includes its source commits, limitations, and an AI-assistance disclosure.
Have a related result or a correction? Contact Orbitus Robotics.